I Behavior in the Control Loop
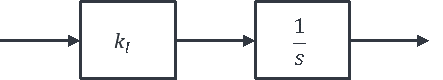
If parameter A shows only I behaviour, we model A with a block for kI and an integrator with 1/s.
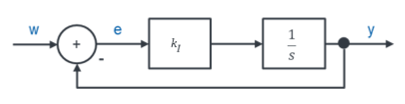
In a control loop, this looks as follows:
\[
\begin{gathered}
H_{\mathrm{FÜ}} = \frac{A}{1 + A} \\[6pt]
A = k_I \cdot \frac{1}{s} \\[6pt]
H_{\mathrm{FÜ}} = \frac{k_I \cdot \frac{1}{s}}{1 + k_I \cdot \frac{1}{s}}
\end{gathered}
\]
It is advantageous to divide the numerator and denominator by A. This gives us a form that is described as a new standard behaviour in the next chapter. So:
\[
\begin{gathered}
\text{General: } H_{\mathrm{FÜ}} = \frac{A}{1 + A} = \frac{1}{1 + \frac{1}{A}} \\[6pt]
\text{Example I behaviour: } A = k_I \cdot \frac{1}{s} \text{ and } \frac{1}{A} = \frac{1}{k_I} \cdot s \\[6pt]
H_{\mathrm{FÜ}} = \frac{1}{1 + \frac{1}{A}} = \frac{1}{1 + \frac{1}{k_I} \cdot s}
\end{gathered}
\]
In the next chapter, we deal with the new behaviour described by the reference transfer function.