Disturbances
The controller drives the actuator. The actuator acts on the plant. This is the intended way in which the system is influenced. All other external influences acting on the controlled variable are called disturbances. This applies regardless of whether they literally “disturb” or perform a normal function in the system.
One goal of control engineering is for the controlled variable to match the reference variable. This also applies when disturbances act on the controlled variable. All previous goals of control engineering also apply in the presence of disturbances.
Disturbances are modelled as input quantities. They can act at different points in the control loop. For the effect of a disturbance on the system, it is crucial where in the control loop it occurs. To start, let us look at two examples of disturbances:
Example 1: bucket
A bucket filled with water has an inlet and an outlet. The inflow is the input quantity. The actuator is the valve that controls the inflow. We want to control the fill level of the bucket, so the fill level is the controlled variable. The “normal” control path sets the fill level via controller and actuator, i.e. via the inflow. The plant is the bucket itself.
The outflow acts on the fill level just like the inflow. But it is not controlled via the controller’s actuator, so it is defined as a disturbance. If water is drained, water must be topped up via the inlet. The amount of water that changes the fill level overall is the difference between inflow and outflow. For inflow and outflow (Zu = in, Ab = out, Eff = effective):
For modelling, we work our way along the formula. Inflow and outflow are first subtracted, and then the result is integrated. In the block diagram, the disturbance outflow acts “to the left” of the integral. The outflow is subtracted from the inflow. The block diagram of controller, actuator, disturbance and plant looks like this:
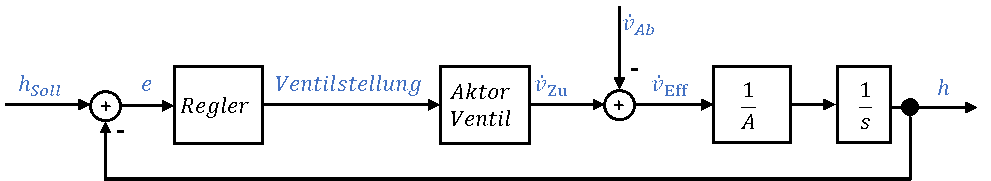
For now, the mathematics only represents the right part of the block diagram, i.e. the part between actuator and controlled variable. We close the control loop mathematically after the next example.
Example 2: cruise control
In the speed control of a car, the engine is the actuator and the vehicle is the plant. Disturbances are, for example, headwind and the gradient of the road. They act as forces on the vehicle. In general, the following relationship between force and speed applies:
So the speed is linked to the force via an integral. If we calculate this in the frequency domain:
Several forces act on the speed. First, the force of the engine, as the output of the actuator, acts on the speed in the direction of travel. When the car drives up a slope, a braking force acts against the direction of travel. Headwind and friction also act as braking forces, i.e. against the direction of the engine force. The disturbing forces act against the engine force, so they are subtracted from it (Steigung = gradient, Reibung = friction, Fahrtwind = headwind, Stör = disturbance).
Let us insert the force equation into the speed equation. The forces are first added to a total force, and this is then integrated. That is why the sum of forces is modelled to the left of the integration in the block diagram.
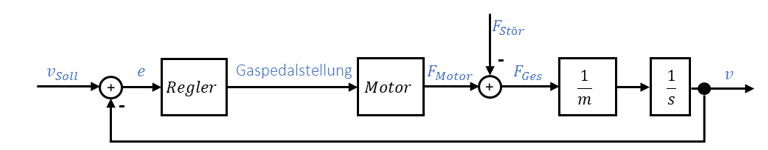
In the model – as in the equations – the forces are subtracted first and then integrated. You can see that the models of the two systems are similar, although they have completely different functions. Next, let us look at how disturbances are calculated in controlled systems.