Learning Content and Theses

Platform for digital learning at HSHL

PT1 Behavior in the Control Loop

Next we look at PT1 behaviour in a control loop. If parameter A shows PT1 behaviour, we obtain the following block diagram:
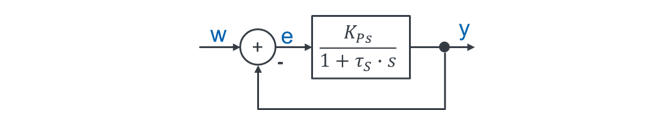
Control loop with PT1 plant k_PS / (1 + τ_S · s)
\[ \begin{gathered} A = \frac{k_{PS}}{1 + \tau_S \cdot s} \quad \text{(subscript S: system without control)} \\[8pt] H_{\mathrm{FÜ}} = \frac{A}{1 + A} = \frac{\frac{k_{PS}}{1 + \tau_S \cdot s}}{1 + \frac{k_{PS}}{1 + \tau_S \cdot s}}\text{, expand by } (1 + \tau_S \cdot s) \\[8pt] = \frac{k_{PS}}{1 + \tau_S \cdot s + k_{PS}} = \frac{k_{PS}}{(1 + k_{PS}) + \tau_S \cdot s}\text{, divide by } (1 + k_{PS}) \\[8pt] = \frac{\frac{k_{PS}}{1 + k_{PS}}}{\frac{1 + k_{PS}}{1 + k_{PS}} + \frac{\tau_S}{1 + k_{PS}}\,s} = \frac{\frac{k_{PS}}{1 + k_{PS}}}{1 + \frac{\tau_S}{1 + k_{PS}}\,s} = \frac{k_{P,\mathrm{FÜ}}}{1 + \tau_{\mathrm{FÜ}} \cdot s} \\[8pt] \text{Subscript FÜ: controlled system in the control loop} \\[8pt] H_{\mathrm{FÜ}} = \frac{k_{P,\mathrm{FÜ}}}{1 + \tau_{\mathrm{FÜ}} \cdot s} \text{ with } k_{P,\mathrm{FÜ}} = \frac{k_{PS}}{1 + k_{PS}} \text{ and } \tau_{\mathrm{FÜ}} = \frac{\tau_S}{1 + k_{PS}} \end{gathered} \]

The reference response also shows PT1 behaviour. However, its characteristic parameters differ from those of the PT1 behaviour of block A. Above all, τFÜ changes. It becomes smaller the larger kPS is. So with kPS we can make the controlled system faster than A.

In the steady state:

\[ H_{\mathrm{FÜ}} = \frac{\frac{k_{PS}}{1 + k_{PS}}}{1 + \frac{\tau_S}{1 + k_{PS}} \cdot 0} = \frac{k_{PS}}{1 + k_{PS}} \neq 1 \]

We have the same problem as with P behaviour in the control loop: for real values of kPS, the reference response is always less than 1. So there is a control error even in the steady state. This is because PT1 behaviour behaves like time-delayed P behaviour. In the steady state, A takes finite values if we insert PT1 behaviour for A. So a control error e must remain in the system.

PT1 behaviour in the control loop is even worse than P behaviour in the control loop. There is a steady-state control error. In addition, after a step there is a large control error in the transition range. P behaviour at least reacts immediately to the step at the output.

Download course as PDF

The PDF contains all pages of the course. Interactive content is only available on the website.