Summary
I behaviour
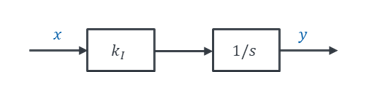
\[
H(s) = \frac{1}{s} \cdot k_I
\]
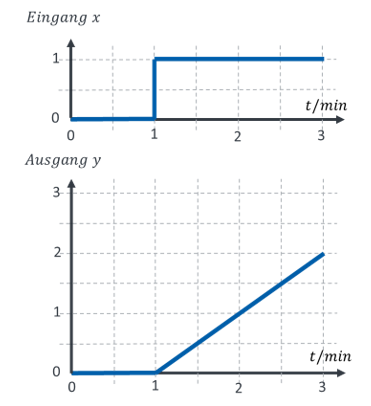
I behaviour in the control loop
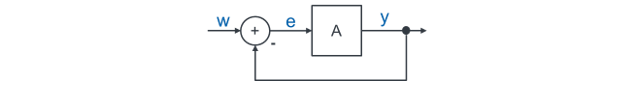
\[
\begin{gathered}
A = k_I \cdot \frac{1}{s} \\[6pt]
H_{\mathrm{FÜ}} = \frac{1}{1 + \frac{1}{k_I} \cdot s} \\[6pt]
H_{\mathrm{FÜ}} = \frac{1}{1 + \tau_{\mathrm{FÜ}} \cdot s} \text{ with } \tau_{\mathrm{FÜ}} = \frac{1}{k_I} \\[6pt]
\text{I behaviour in the control loop} \rightarrow \text{PT1 behaviour of the controlled system}
\end{gathered}
\]
PT1 behaviour
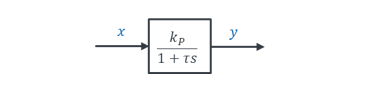
\[
H(s) = \frac{k_P}{1 + \tau s}
\]
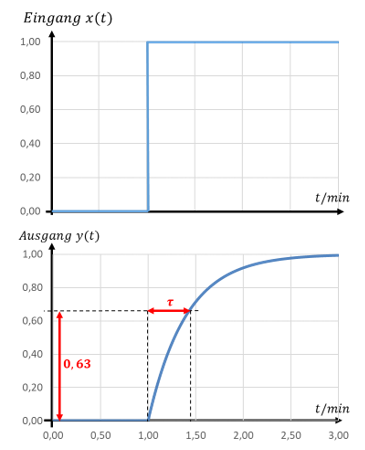
PT1 behaviour in the control loop
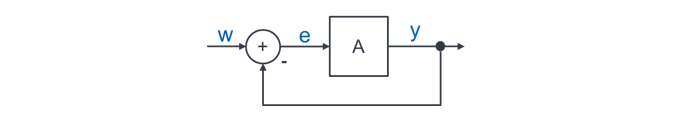
\[
\begin{gathered}
A = \frac{k_P}{1 + \tau s} \\[6pt]
H_{\mathrm{FÜ}} = \frac{\frac{k_P}{1 + k_P}}{1 + \frac{\tau}{1 + k_P}\,s} = \frac{k_{P,\mathrm{FÜ}}}{1 + \tau_{\mathrm{FÜ}} \cdot s} \\[6pt]
k_{P,\mathrm{FÜ}} = \frac{k_P}{1 + k_P} \\[6pt]
\tau_{\mathrm{FÜ}} = \frac{\tau}{1 + k_P} \\[6pt]
\text{PT1 behaviour in the control loop} \rightarrow \text{PT1 behaviour of the controlled system}
\end{gathered}
\]
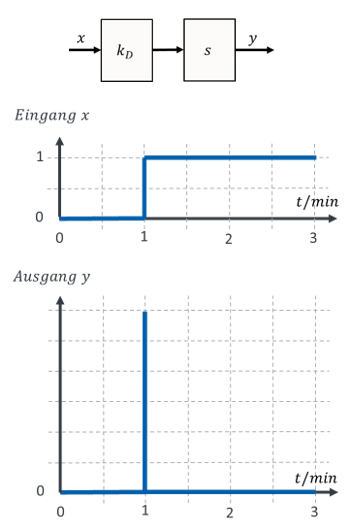
D behaviour
\[
H_D = k_D \cdot s
\]
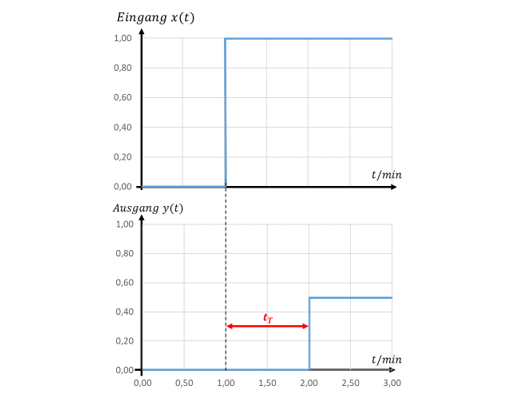
Dead time
\[
\text{Dead time } t_T = 1\,\mathrm{min} \text{ for a system with P behaviour and } k_P = 0.5
\]
In general: the behaviour describes a type of behaviour of a function block or system. We treat the mathematical description of all systems with the same behaviour in the same way. They differ only in their characteristic parameters. With the characteristic parameters we describe something like the intensity of the behaviour.